Overall-Setup
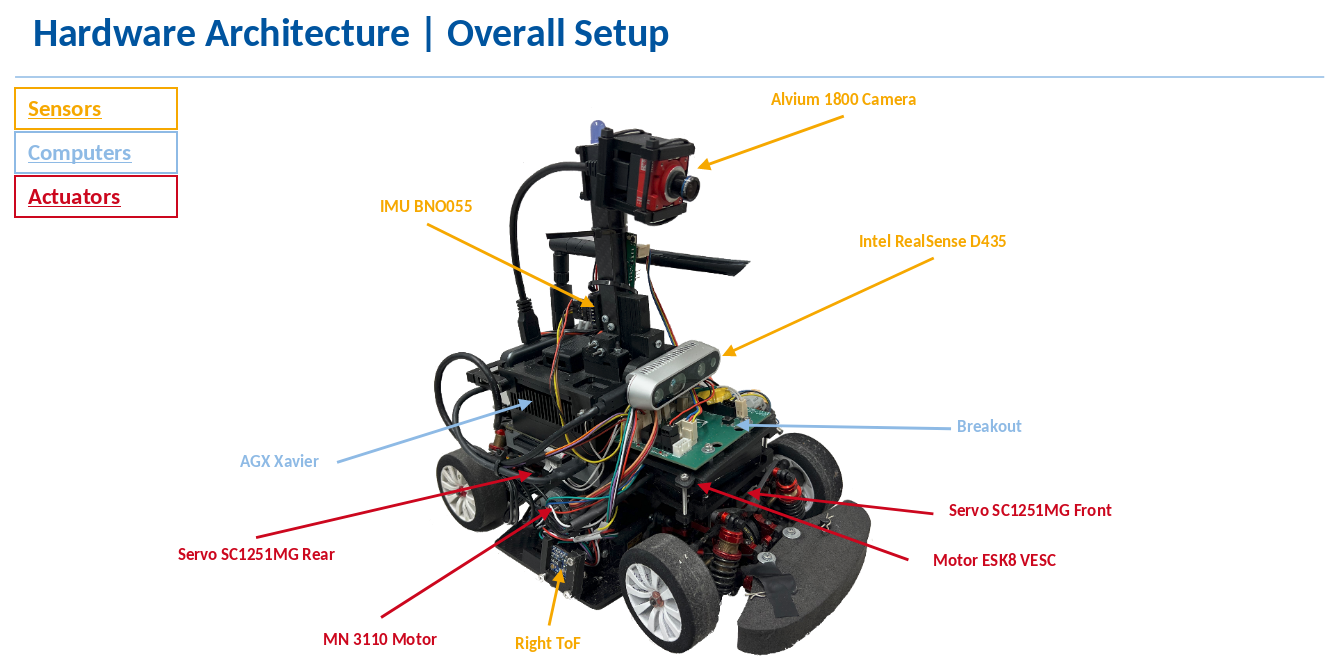
Due to our small team size and the addition problems of procuring parts during the pandemic, we decided to make only necessary changes to the car and focus on software.
Our car has two steerable axis and has a very small turning circle to aid with parking. It also has all wheel drive using a single motor.
For sensing the environment, it is equipped with a regular RGB Camera and a Depth Camera, an IMU and TOF sensors.
- The AGX perceives the environment based on the sensor and camera data, performs inference tasks on the data and finally calculates the reference speed and steering angles, so that the car is able to follow the track autonomously without human involvement.
For autonomous operations it is equipped with two computing units:
- The first is a self-developed breakout board that communicates with the front and rear servo, the motor ESC, IMU, rpm and ToF sensors and acts as a bridge between the hardware and the main computing unit.
- The second, main computing unit is an nVidia AGX Xavier that is directly connected to the rgb and depth camera.
When necessary, control of the car can be seized at any time via the remote control. And can also be returned to the car.