Sensors-and-Actuators
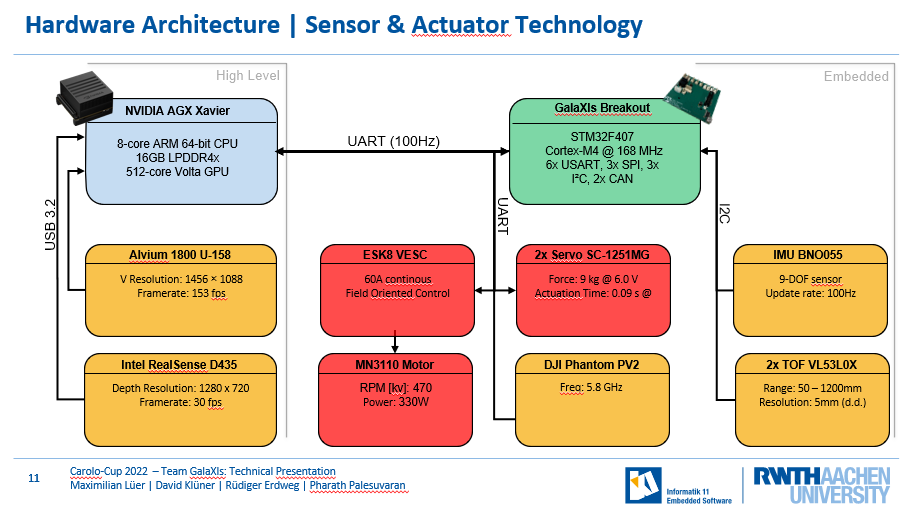
Our main computing unit, the Nvidia AGX Xavier is responsible for compute intensive tasks like environment detection, planning and high-level control.
Our secondary compute unit, the STM32 on our Breakout board communicates with embedded sensors and actuators, as well as our RC receiver.
The communication between these two computers operates at 100Hz using UART.
We deceided to use the Nvidia AGX Xavier in contrast to a less powerful computer because we wanted less performance overhead and the option to deploy more deep learning solutions.
We also think that the use of two systems offers significant advantages, as this two system architecture allows us to swap main compute units while only having to reimplement the single UART Interface.
The Breakout Board is connected to the motor, VESC, servo, DJI Phantom PV2, IMU and both ToF sensors.
- Note: In particular, the board is connected to the DJI Phantom PV2 receiver. Thus, the board acts as an interface between the remote control and the motor.